Learning from Humans
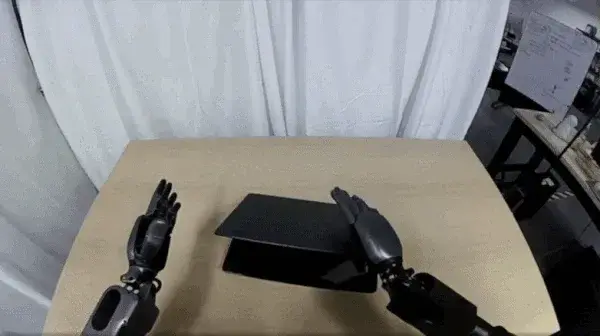
Our models learn by watching videos of humans, providing a scalable approach to collecting data for robotics.
The intelligence layer for physical AI — one model that operates any robot body, on any task, in the places people can no longer staff.
A single perception–reasoning–control model. Not one stack per robot, per customer, per site.
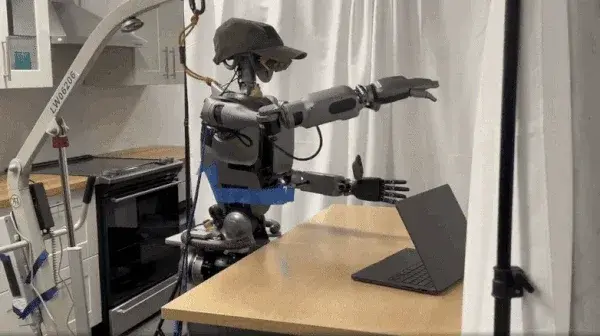
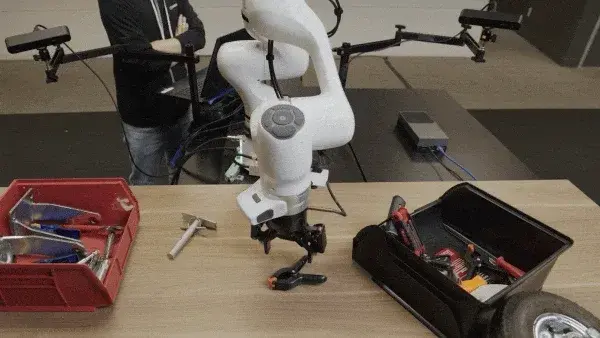
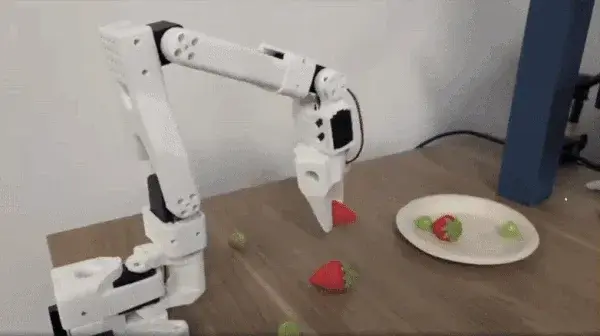
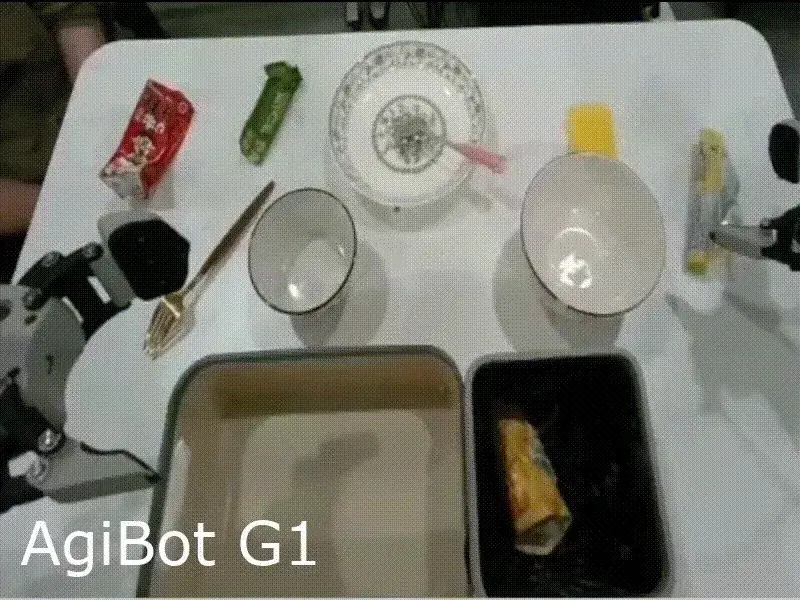
Hardware-agnostic by design. Quadruped, humanoid, wheeled base — same brain, different body.
Skills are learned and shared, not hand-coded. A new task takes days, not a new engineering project.
Physical AI should be omni-bodied.
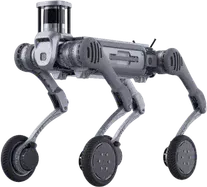
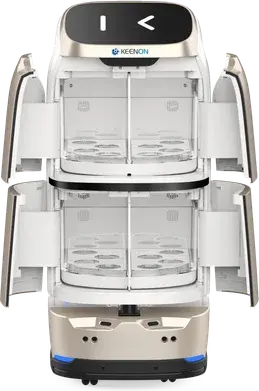
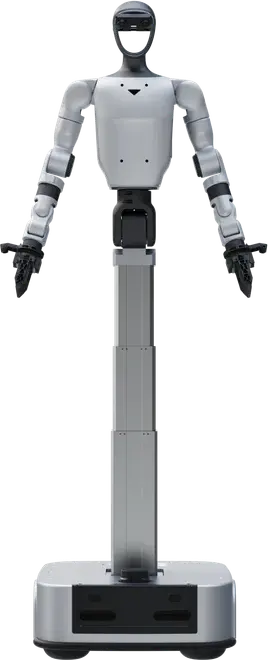
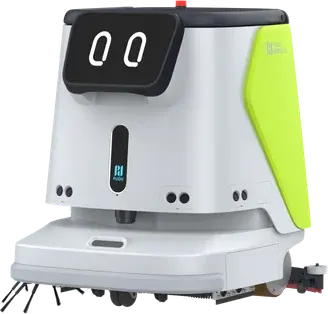
Our models learn by watching videos of humans, providing a scalable approach to collecting data for robotics.
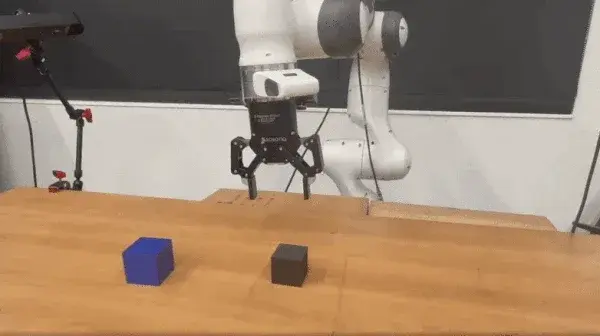
Our robotics foundation model is designed to scale and can be adapted to any hardware and task, ensuring reliable performance.
A unified robotic brain that powers different bodies and adapts to a wide range of tasks.
Our end-to-end vision model maps raw camera input directly to motion, enabling agile, autonomous navigation in complex environments.
Teleoperation, human demonstration, simulation, and real-robot rollouts across arms, humanoids, and mobile platforms feed one shared model.
Tell us about your operation and we'll map out the right platform, deployment, and support path with you.